Interview with Dr. Pablo Oliveira Antonino, Department Head Virtual Engineering at Fraunhofer IESE
Software is increasingly becoming a key driver of innovation in vehicle development. With the shift toward Software-Defined Vehicles, architecture, development processes, and validation are undergoing fundamental changes. Digital twins and simulation play a key role in this. In this interview, Dr. Pablo Oliveira Antonino explains what this transformation process looks like in practice and what opportunities it presents.
Why does software play such a central role in vehicle development today?
The automotive industry is undergoing a fundamental transformation: vehicles are evolving from electromechanical products into software-driven systems. This is no longer a vision, but reality.
Is the Software-Defined Vehicle a new concept – and what specifically defines it?
The underlying principle has existed for more than ten years. What is new is not so much the idea as the consistency with which it is being implemented today. In the past, safety-critical functions were implemented very conservatively and with a heavy reliance on electromechanical systems. Today, control and logic run through numerous controllers and computers within the vehicle. A customer from the commercial vehicle sector once put it aptly: “We were a mechanical engineering company – and suddenly we’re a software company.”
A Software-Defined Vehicle is a vehicle whose functionality is primarily determined by software. The hardware becomes a standardized platform. Our digital twins and simulations are particularly relevant in this context. They enable predictive validation of complex systems and significantly reduce development and integration risks. Without scalable virtual testing, the development of modern Software-Defined Vehicles would be economically unsustainable.
Why are real-world tests no longer sufficient for modern vehicles?
The complexity is simply too high. For autonomous or semi-autonomous vehicles, studies show that to test all relevant scenarios in real life, a vehicle would have to travel a distance equivalent to 88 times the distance between earth and the sun. That is obviously impossible. Virtual validation is therefore the only option and an absolute prerequisite.
What added value does the driving simulator offer in validation?
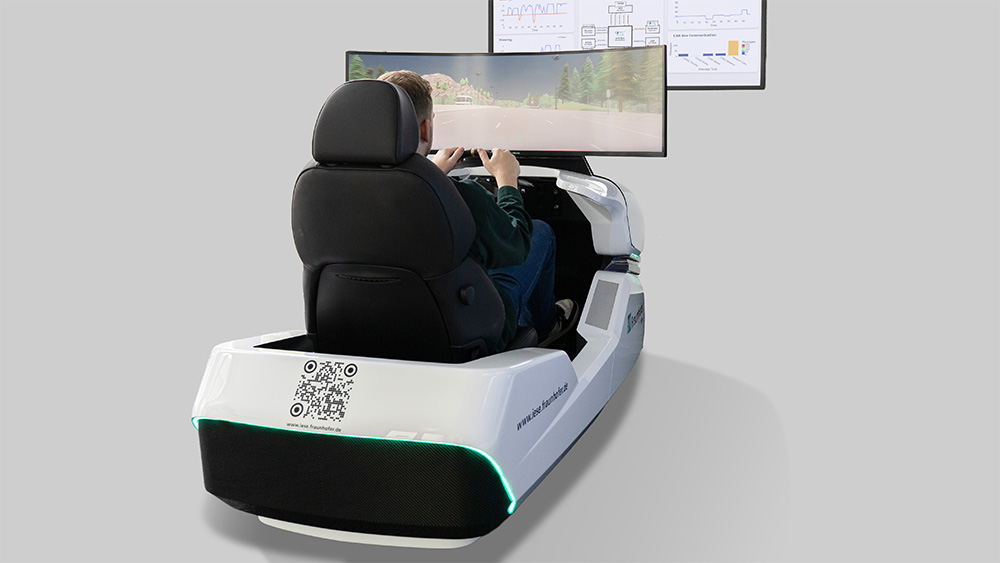
The driving simulator is an important development tool for us. It integrates digital twins and algorithms into realistic driving scenarios. We can introduce specific disturbances and observe how the vehicle behaves – not just in the code, but in a way that is perceptible to the driver. This concept is referred to as “X-in-the-Loop”. This makes complex interactions understandable and tangible.
“Without scalable virtual testing using tools like FERAL, the development of modern Software-Defined Vehicles would be economically unviable.”
Dr. Pablo Oliveira Antonino, Department Head Virtual Engineering
What makes FERAL a key tool?
Fraunhofer FERAL is a modular simulation and co-simulation framework developed at Fraunhofer IESE. It enables the creation of digital twins of embedded assets and integrates software functions, network models, and E/E platforms into a common co-simulation environment. A key feature is targeted fault injection, which enables early fault detection and systematic verification. This reduces the need for physical prototypes, shortens validation cycles, and significantly accelerates the time-to-market for vehicles.
Why is this approach particularly relevant for commercial vehicles?
Commercial vehicles often operate in highly specialized and unpredictable operating environments – such as in agriculture, mining, or on construction sites. Downtime here immediately results in economic damage. Many of these vehicles are essentially “factories on wheels.” If a system fails, in the worst-case scenario, an entire value chain comes to a standstill. This is precisely where the special added value of software-driven vehicle architectures becomes apparent.
Are there concrete real-world examples from industry?
One successful project is our collaboration with the South Korean company Perseus Co., Ltd. We are working together on solutions for Software-Defined Vehicles, particularly on the virtual validation of hypervisor technologies. A hypervisor coordinates multiple operating systems on a shared hardware platform. We use FERAL to build digital twins to validate complete system architectures – including software, hardware, and communication – at an early stage. This allows us to analyze performance, robustness, and resource conflicts in a virtual environment.
We also have a long-term partnership with the American company Balanced Engineering LLC. As business partners, we combine our expertise in virtual engineering and jointly bring it to international markets. For example, we have implemented a project for the virtual validation of autonomous vehicles in agriculture. To this end, a simulation environment was created that replicates realistic agricultural scenarios – such as varying weather conditions and obstacles. This reduces the need for expensive field tests and increases the efficiency of autonomous agricultural systems.
We also collaborate successfully with John Deere GmbH & Co. KG on the next generation of autonomous agricultural machinery and digital farming technologies. Our joint work focuses on the application of Digital Twins, co-simulation, and AI-enabled capabilities within connected vehicle architectures. A particular emphasis lies on the intelligent orchestration of software and AI functions across vehicle, edge, and cloud platforms, enabling efficient, dependable, and scalable autonomous operations. This collaboration demonstrates how virtual engineering and validation technologies can accelerate innovation and support the practical deployment of future agricultural systems.
What does all this mean for the future of autonomous driving?
When digital twins and simulation are consistently applied, vehicles emerge that are safer, more cost-effective, quicker to repair, and functionally more flexible. This makes autonomous driving realistic and manageable – even though regulation and societal acceptance naturally play a role as well.
What challenges are you facing in the transition to software-defined vehicles?
From digital twins to co-simulation and fault injection:
In the field of virtual engineering, we bridge the gap between cutting-edge research and industrial applications.
Leverage our expertise to validate your software systems.